The common continuum hierarchy
Two bound families enter compact extraction. One is available at each fixed physical period, with constants allowed to depend on that period. The other holds uniformly over sufficiently large periods, eventually in the mesh at each such period. The second is supplied separately; it is not a consequence of the first. The full inner Cauchy limit and the compact selection are identified before the outer period refinement is taken.
From convergent transported coefficients to fixed-level integrals
Fix the intermediate level , period
 , degree
 , and an insertion coefficient
 . Along the chosen increasing finest cutoffs, the transport construction gives a Cauchy sequence of primary coefficient vectors and a Cauchy sequence of captured interaction coefficients on one common dictionary at level
 . The latter statement includes equality between each captured coefficient’s realization and the interaction part of that same transported insertion. Thus coefficient convergence is applied to the actual transported insertion, rather than to an independently chosen representative.
The coefficient-to-observable estimates convert these two Cauchy statements into uniform boundedness and uniform Cauchy convergence over all configurations, both for the primary insertion and for every forced local profile. Spatial pullback, conjugation when required by the motion, and multiplication by its fixed scalar preserve these properties. Boundedness of a Cauchy coefficient sequence also bounds its paid coefficient norm, since that norm is a fixed scalar times a continuous finite-dimensional norm. Measurability follows from the local continuous terms, the measurable masking functions and the convergent countable sums in the insertion formulas. Continuity of the masks is not used.
To see how this enters the normalized integral, remove the scalar vacuum factor from the restored density and denote the result by ). Its mode coefficient factors as the cold density times the selected coefficient of a product: the polynomial exponential of the primary insertion, and the field
polynomial built from the background activities plus the forced profiles with the prescribed flags. The fixed-level flux bounds give uniform Cauchy convergence for the cold densities and background field polynomials. The preceding insertion bounds do the same for primary and forced profiles. Finite sums, products and continuous maps on common compact bounded ranges preserve uniform Cauchy convergence, so every mode of has that property.
Integration against the probability Haar prior therefore gives Cauchy numerator integrals. The stripped partition functions are Cauchy as well and have a common strictly positive lower bound, as proved earlier. Completeness gives their limits; the lower bound makes the denominator limit nonzero. Taking the quotient proves that the normalized mode integrals are Cauchy. Finally, the scalar vacuum factor cancels exactly in numerator and denominator: this quotient equals the common-normalization integral of the restored insertion. This is the link between the fixed-level coefficient construction and the earlier fine-to-intermediate comparison. The transport recurrence and captured-coefficient estimates are proved in the fixed-level convergence sections below.
Identification of the public hierarchy with the reconstructed one
The final public projection introduces no second quantum field system. Its Hilbert space is the reconstruction’s completed state space, its common domain is the reconstructed word domain, its vacuum is the reconstructed vacuum, and its field operator is the same operator on that domain. The label space is the union of the graded field spaces already obtained from the continuum table. The phase space and probability measure are those of the character decomposition. For a character  , the public separated correlation is the table’s evaluation in that character; the unselected correlation is the table’s unselected evaluation. The OPE reader supplies the channels, channel fields and coefficients. These identifications keep the lattice limits, OPE terms and reconstructed fields attached to the same table.
The equality of vacuum moments can be checked without any limiting interchange: recursively evaluating a list of smeared fields in the public definition gives the identical reconstructed word vector, starting with the same vacuum. Taking its inner product with the vacuum proves equality of the moments. Similarly translations are the original strongly continuous translation operators and the energy-momentum measure is the original projection-valued measure. A Poincaré transformation is represented by its Lorentz matrix and translation vector; its test action is the original inverse affine pullback. Thus the public covariance and spectral assertions follow by literal substitution once their reconstructed counterparts have been proved.
Each graded field injects into the label space by the table’s pin map. Every label has a graded representative by the field-covering property; every graded field has an insertion-token representative by the table’s quotient representative map. These are separate surjectivity assertions. Non-triviality follows from the degree-zero unit: its image is nonzero by injectivity and the unit’s nonvanishing; faithfulness then supplies a Schwartz test with nonzero field operator. The boundary label-quotient argument in the reconstruction chapter proves faithfulness.
For separated configurations, a whole word can be placed in one of the decomposition’s resolved configurations. The character evaluation of that resolved word is continuous in the character by the decomposition’s weak continuity property. Its integral equals the unselected word expectation by the barycenter identity. Reading that word through the table gives both character continuity and the public mixture formula. The compression-valued moments and character readings in the reconstruction chapter provide the resolved-word placement and barycenter identities used here.
The analytic continuation used publicly is the reconstruction’s holomorphic wave evaluated on the pinned graded labels. At strictly ordered Euclidean times, assembling the spatial coordinates and times reconstructs exactly the original four-dimensional configuration, so the heat-root iden-
tity gives its selected Euclidean value. For the boundary limit, materialize the product of Schwartz tests as one joint test. The public complex shift is exactly the reconstruction’s shift by the ordered height vector
 . Its boundary theorem therefore gives the required vacuum moment. The substantive holomorphy, heat-root and boundary-existence arguments remain part of the reconstruction proof, rather than consequences of these notational identifications.
Compatibility of the chosen family and its refinements
The construction chooses its Wilson family before a volume subsequence or an observable is requested. The explicit order of its pre-length floors, post-length numerical bills and countable width demands is (CAL12)–(CAL18). Their consumption gives the flat delay condition at entrance index zero on the run’s actual horizon, as proved there. The same fixed family is used below.
At the continuum extraction stage there are two successive refinements of a requested order f. The first chooses a subsequence g along which the running reference parameters have limits at each fixed level. The second extraction gives a subsequence w, one continuum table, its final structure F and scaling fields. Use the composite refinement . Every convergence assertion from the first extraction survives the second, because a strictly increasing natural sequence tends to infinity. Composition of the subsequence maps gives (
 ), so all conclusions have precisely the same final volume order.
On that final table choose the reconstruction for every character, one equivariant OPE reader, and the trace test. The reader’s coefficients and local fields are retained as one prescription at every truncation degree; the contact devices are then chosen with that same reader basis. This is the quantifier order used by the public theorem and its detailed extension. The preceding construction estimates and the subsequent reconstruction, operator-product and trace arguments establish these services on the retained table. The compatibility argument here proves that using these supplied results together preserves their actual family, table and subsequence, rather than treating unrelated existence witnesses as interchangeable.
Extending the full fixed-volume mesh limit
At fixed intermediate level the configuration space is fixed, and the source’s Confluence condition means eventual uniform boundedness and uniform Cauchy convergence in that configuration variable. Finite sums and products preserve it. A continuous map preserves it when the range lies in a common compact set: uniform continuity on that compact set controls the Cauchy modulus. In particular continuous polynomial coordinate maps preserve it for the finite insertion algebra. For eventually measurable functions on the fixed Haar probability space, uniform boundedness gives integrability and
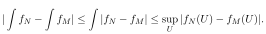
Searchable transcription
|
Z
fN −
Z
fM| ≤
Z
|fN −fM| ≤sup
U
|fN(U) −fM(U)|.
Searchable transcription
Thus the integrals are Cauchy. The finite polynomial insertion numerator is built from the
scalar-normalized density, transported primary insertions and local error insertions by exactly these
operations. Its Confluence follows from the corresponding fixed-level field and density statements.
The scalar-normalized partition integrals are likewise Cauchy.
Their common positive lower bound is kept before division. At fixed level j and volume p, let
E be the number of sites, v the positive small-field threshold, H = 2 bβj, and let K be the uniform
upper bound for the action and activity costs on the selected small-field neighborhood. Write Dmat
for the fixed finite real matrix-coordinate dimension entering this estimate, denoted dimR Mat(G)
in the supplied notation. Its precise value is not used in the quotient argument; the lower bound is positive for every such fixed finite dimension. The denominator estimate gives

Searchable transcription
exp[−K −#Edges Dmat log(16/v)]
for the scalar-stripped partition function, independently of the finer cutoff . Its equality to the fixed-level normalized denominator follows from the selected trajectory’s partition identity. The numerator and denominator limits therefore form a valid convergent quotient. Write
 for the represented scalar vacuum term. The factor
 cancels exactly in this quotient, recovering the represented expectation. This proves the fixed-level ratio convergence once the uniform density and insertion convergence and the small-field denominator estimate have been established by the nonlinear construction.
The Taylor bound used here follows from bounds on two further lattice differences. On a compact collision-free K, choose a compact thickening still disjoint from collisions. All first differences of a fixed difference word are bounded there. A coordinate-by-coordinate lattice path joining two nearby mesh points stays in this thickening and has at most a fixed dimension factor times their physical distance divided by steps. Telescoping the first differences along the path gives a local Lipschitz bound for the word. Apply this to each first difference, using its own first differences, to obtain a common Lipschitz constant A for the discrete gradient. Subtract the affine function with that gradient frozen at the starting point. Each unit difference of the residual is
 times the change in the gradient, hence bounded by
 A times the total endpoint distance. A second path telescope gives a dimension factor times A times the squared endpoint distance. This is the uniform quadratic Taylor estimate above. FixedBounds supplies every fixed finite difference order, so the two extra derivatives are available without changing the physical volume.
One can obtain the next-difference limit without selecting another mesh subsequence. Fix x, a coordinate a and 0. Choose a positive physical displacement q small enough to stay inside the compact neighborhood and to make Bq small compared with
 , where B is its Taylor constant. Put
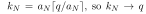 and eventually
 . The long difference quotient of the known convergent word between its address near x and that address shifted by
 is Cauchy, because both endpoints have cluster limits and
 0. The quadratic Taylor estimate places its distance from the unit next-difference value at x below
 . Choose q first to make this error
 4; then take N,M large enough that the two long difference quotients differ by
 2. The next unit-difference sequence is Cauchy at x. Its eventual oscillation bound follows from the preceding local Lipschitz estimate and the
 ) error of mesh addressing. The dense-set extension lemma, now applied to this derivative sequence at every x, gives its locally uniform limit along the original mesh sequence. Repeating proves the existence of all next limits used in the derivative-identification argument.
The discrete-to-classical derivative identification uses a quadratic Taylor bound. Suppose is the locally uniform limit of the lattice difference word l, and
 is a locally uniform limit of its next coordinate difference. The fixed bounds supply, on a compact neighborhood, a uniform estimate
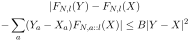
Searchable transcription
|FN,l(Y ) −FN,l(X)
−
X
a
(Ya −Xa)FN,a::l(X)| ≤B|Y −X|2
for physical lattice points sufficiently close together. Approximate real points x,y by their mesh addresses. Pass to the limit in the inequality to obtain
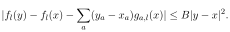
Searchable transcription
|fl(y) −fl(x) −
X
a
(ya −xa)ga,l(x)| ≤B|y −x|2.
Searchable transcription
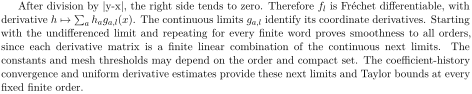
After division by |y-x|, the right side tends to zero. Therefore fl is Fréchet differentiable, with
derivative h 7→P
a haga,l(x). The continuous limits ga,l identify its coordinate derivatives. Starting
with the undifferenced limit and repeating for every finite word proves smoothness to all orders,
since each derivative matrix is a finite linear combination of the continuous next limits.
The
constants and mesh thresholds may depend on the order and compact set. The coefficient-history
convergence and uniform derivative estimates provide these next limits and Taylor bounds at every
fixed finite order.
The result is independent of the particular fixed forward, backward or centered stencil. For nonnegative integers b,f with 0, the normalized difference
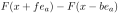
Searchable transcription
F(x + fea) −F(x −bea)
 is the arithmetic average of the e unit forward differences based at
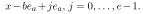 Unit differences commute with these finite translation averages. Iterating expresses any finite mixed stencil word as a finite average of the corresponding unit-difference word. Every averaged argument has physical displacement
 ) and hence the same limiting physical point. The cluster limit is therefore the same derivative, with no extra stencil-length factor. This proves the claimed normalization for all fixed reach stencils.
Searchable transcription
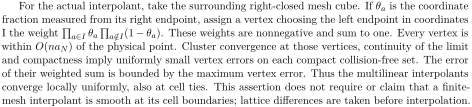
For the actual interpolant, take the surrounding right-closed mesh cube. If θa is the coordinate
fraction measured from its right endpoint, assign a vertex choosing the left endpoint in coordinates
I the weight Q
Q
a∈I θa
a/∈I(1 −θa). These weights are nonnegative and sum to one. Every vertex is
within O(naN) of the physical point. Cluster convergence at those vertices, continuity of the limit
and compactness imply uniformly small vertex errors on each compact collision-free set. The error
of their weighted sum is bounded by the maximum vertex error. Thus the multilinear interpolants
converge locally uniformly, also at cell ties. This assertion does not require or claim that a finite-
mesh interpolant is smooth at its cell boundaries; lattice differences are taken before interpolation.
The dense-position Cauchy argument uses a second uniform approximation. Let denote the fine-cutoffmoment for a fixed separated configuration. At a fixed intermediate level j, replace it by its transported moment
 . The fixed-level confluence estimates make
 Cauchy in N. The comparison theorem bounds
 by a fixed finite cost divided by a scale function
 uniformly for all sufficiently large N. To use that theorem simultaneously for a finite word, choose positive weights
 + 1), where
 bounds the charged coefficient cost and
 is its allowed margin. Then
 times the charged cost is at most
 . The finite collection of transported
observables and localized errors has one eventual weighted bound by summing its individual bounds. This supplies the common comparison cost. Choose j making the uniform error below /4, then N,M large enough that
 4. The triangle inequality proves the Cauchy property of
 . The convergence-of-histories chapter establishes the confluence and comparison estimates used in this argument.
The equicontinuity lemma used in the fixed-volume construction does not require that the approximating functions themselves be continuous. Let U be open in a locally compact metric space and let have eventual uniform oscillation bounds on each compact
 : for every
 0 some
 0 makes
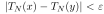 for all sufficiently large N and
 with distance less than
 . Assume
 ) is Cauchy on a dense subset
 . For an arbitrary x choose a compact neighborhood
 and a dense point d within the oscillation radius. Then
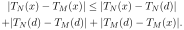
Searchable transcription
|TN(x) −TM(x)| ≤|TN(x) −TN(d)|
+|TN(d) −TM(d)| + |TM(d) −TM(x)|.
Taking all three terms below /4 proves the Cauchy property at x. Completeness of
 gives a pointwise limit f. Passing to the limit in the oscillation estimate proves continuity of f. If convergence failed uniformly on a compact K, choose
 and
 whose errors stay above a fixed
 . A convergent subsequence
 , the oscillation bound for
 , pointwise convergence at x and continuity of f contradict that error. Thus
 locally uniformly on U, with no mesh refinement.
In the source U is the periodic collision-free position set at a fixed physical volume. The nonlinear bounds supply its oscillation estimate. The dense set is the schedule-compatible set of ancestor positions. At those positions the common-history comparison gives the Cauchy property for the full mesh sequence; the two-level approximation and fixed-level confluence arguments give this Cauchy property. The preceding lemma then extends this full-sequence convergence to all of U. The Taylor and next-difference arguments above identify all derivative limits and prove smoothness.
To pass a known cluster limit of lattice values to tests, express the lattice sum as the integral of the piecewise constant function on the physical lattice cells. Each cell has volume
 , exactly the mesh prefactor in the sum. The compact test support stays inside a suitable physical period box and away from collisions. Cluster convergence gives an eventual uniform bound on all lattice values whose physical positions lie in this compact support: otherwise choose an unbounded sequence of such values, extract a convergent sequence of physical positions in the compact set, and contradict the cluster limit. The test is uniformly bounded, so these piecewise constant integrands have one
integrable bound on the fixed volume box. The sampled physical positions converge to each point, and continuity of the test and the cluster limit gives pointwise convergence. Dominated convergence therefore yields the integral of the test against the limiting correlation. The same argument applies to every already identified derivative cluster limit. This proves the smearing passage once those cluster limits have been established.
Searchable transcription
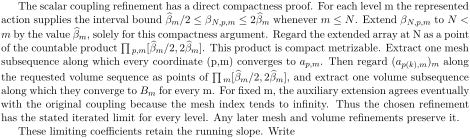
The scalar coupling refinement has a direct compactness proof. For each level m the represented
action supplies the interval bound bβm/2 ≤βN,p,m ≤2 bβm whenever m ≤N. Extend βN,p,m to N <
m by the value bβm, solely for this compactness argument. Regard the extended array at N as a point
of the countable product Q
p,m[ bβm/2, 2 bβm]. This product is compact metrizable. Extract one mesh
subsequence along which every coordinate (p,m) converges to ap,m. Then regard (ap(k),m)m along
the requested volume sequence as points of Q
m[ bβm/2, 2 bβm], and extract one volume subsequence
along which they converge to Bm for every m. For fixed m, the auxiliary extension agrees eventually
with the original coupling because the mesh index tends to infinity. Thus the chosen refinement
has the stated iterated limit for every level. Any later mesh and volume refinements preserve it.
These limiting coefficients retain the running slope. Write
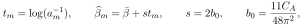
Searchable transcription
tm = log(a−1
m ),
bβm =  ̄β + stm,
s = 2b0,
b0 = 11CA
48π2 ,
where is the adjoint Casimir fixed in the conventions. For every
 0 and all sufficiently large
 , actual-history running gives
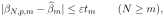
Searchable transcription
|βN,p,m −bβm| ≤εtm
(N ≥m),
Searchable transcription
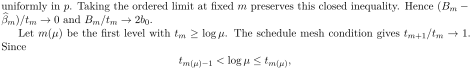
uniformly in p. Taking the ordered limit at fixed m preserves this closed inequality. Hence (Bm −
bβm)/tm →0 and Bm/tm →2b0.
Let m(μ) be the first level with tm ≥log μ. The schedule mesh condition gives tm+1/tm →1.
Since
tm(μ)−1 < log μ ≤tm(μ),
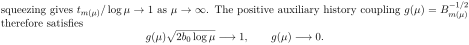
Searchable transcription
squeezing gives tm(μ)/ log μ →1 as μ →∞. The positive auxiliary history coupling g(μ) = B−1/2
m(μ)
therefore satisfies
g(μ)
p
2b0 log μ −→1,
g(μ) −→0.
This concerns the coupling read from the represented history. Its identification with a separately defined position-space diagnostic requires the corresponding comparison theorem and is not made by this scalar compactness argument.
Common compact extraction and the field quotient
The physical field space is a quotient by the equation image, followed by identification through the complete spectator detector. Uniformly bounded projections permit its finite-dimensional coordinates to be retained on the common extraction. Kernel dimension stability uses closeness of idempotents: if ker
 and
 1, then
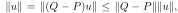 hence
 = 0. Applying the same argument in the opposite direction gives equality of the two kernel dimensions. Inclusions and derivatives descend only after their compatibility with this equation image has been proved.
We describe explicitly the compactness step that puts the preceding estimates on one continuum table. It has two different inputs. At every fixed physical period , each fixed finite list of insertions has eventual centered root bounds, with constants allowed to depend on
 . Separately, on sufficiently large periods there are centered bounds uniform in those periods, eventually in the mesh at each period. The nonlinear insertion estimates give both inputs. The second is not inferred from the first.
Here is the bound for an ordinary correlation derived from these centered bounds. Fix insertions and a compact separated set of physical positions, with separation margin
 0. Choose an intermediate spacing
 , and then a finer reporting level
 so that 6
 . The stencil of each insertion fits its reporting chamber at every sufficiently fine mesh, uniformly in the period: each fixed integer stencil offset times the fine spacing tends to zero, whereas
 0 is fixed. Include the finitely many signed images and reflected insertions in the common centered bound

Choose the origin of the -tiling so that all
 insertion points have distance at least three reporting widths from its chamber boundaries. The inequality 6
 leaves an allowed origin in each coordinate. Separation and
 place the insertion points in distinct chambers. Pull each chamber back to the reference chamber, with its prescribed signed motion and optional conjugation. The insertion locality and stencil fit give genuine chamber-supported functions, and each has rooted bound at most
 . The reflection-positive chessboard inequality therefore gives

Searchable transcription
|⟨I1(x1) · · · In(xn)⟩| ≤An.
(CV1)
This argument applies to arbitrary separated tuples; it does not require every coordinate projection of the tuple to be separated.
For equicontinuity first work on the open set of tuples whose coordinate projections are pairwise distinct, using periodic coordinate differences at a fixed volume. Choose a compact thickening within that open set and a margin 4 for all its projected gaps. The centered translation-difference estimate, with a reporting spacing below
 , bounds a displacement
 of one slot in one coordinate by
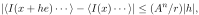

For two nearby tuples change their 4 coordinates one at a time. Each intermediate tuple is obtained by choosing coordinates from one endpoint or the other, so its distance from either endpoint is at most their distance. It stays in the chosen thickening. Summing the 4
 one-coordinate bounds
gives a local Lipschitz constant 4 . The same construction is available at each fixed period and, separately, uniformly in all sufficiently large periods.
Searchable transcription
Only countably many functions need be selected. At each degree choose a finite basis of the label
space and take finite words in these basis vectors, all arities, and a countable compact exhaustion
of their generic position sets. Multilinearity recovers arbitrary labels from these basis words after
selection. Boundedness (CV1) and the equicontinuity estimate give, by the countable local Arzelà–
Ascoli argument, a common mesh subsequence with a locally uniform limit Mp for every fixed
p. Apply the large-period bounds to these limits: passing a boundedness or oscillation inequality
through the mesh limit preserves it. A second countable Arzelà–Ascoli selection along the requested
period sequence gives a table S, locally uniformly on generic configurations. All degrees and words
use these same two selections.
Searchable transcription
For clarity, the countable compact selection itself introduces no hidden uniformity assumption.
If the i-th coordinate lies eventually in a compact set Ki, choose one of its values in Ki and replace
its exceptional earlier values by that value. The resulting sequence belongs to the countable compact
product Q
i Ki, which is compact metrizable in the cases used here. A convergent subsequence in
that product converges in every coordinate. The replacements are eventually absent in each fixed
coordinate, so the original sequence has the same coordinate limits.
This also retains additional countable numerical data ). For every active pair (
 ), first use its own compact fixed-period bound and select their mesh limits
 ) simultaneously. For each
 , a separate compact set
 bounds
 ) at all sufficiently late periods and sufficiently fine meshes at each such period. Closedness of
 puts
 eventually in
 . A common period subsequence then gives
 for every
 . Fixed-period limits are kept at every active
 , including periods absent from the selected period sequence. Apply this construction to the finite-dimensional coordinate projections and the coupling data used above.
Here is the construction and uniform bound for those finite-cutoffprojections. At degree let
 be the image of the free equation ideal under the exact calibrated label map already constructed. This is a subspace of the single fixed coefficient space
 , although it varies with
 . Choose once a linear coordinate isomorphism
 , with Euclidean norm on its source, and let
 be orthogonal projection onto
 . Put

Searchable transcription
FK = I −WπKW −1.
(CVP1)
It kills , and
 for every
 . Moreover

Searchable transcription
∥FK∥≤∥I∥+ ∥W∥∥W −1∥,
(CVP2)
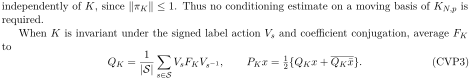
Searchable transcription
independently of K, since ∥πK∥≤1. Thus no conditioning estimate on a moving basis of KN,p is
required.
When K is invariant under the signed label action Vs and coefficient conjugation, average FK
to
QK = 1
X
s∈S
VsFKVs−1,
PKx = 1
2{QKx + QK  ̄x}.
(CVP3)
|S|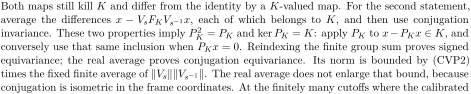
Searchable transcription
Both maps still kill K and differ from the identity by a K-valued map. For the second statement,
average the differences x −VsFKVs−1x, each of which belongs to K, and then use conjugation
invariance. These two properties imply P 2
K = PK and ker PK = K: apply PK to x−PKx ∈K, and
conversely use that same inclusion when PKx = 0. Reindexing the finite group sum proves signed
equivariance; the real average proves conjugation equivariance. Its norm is bounded by (CVP2)
times the fixed finite average of ∥Vs∥∥Vs−1∥. The real average does not enlarge that bound, because
conjugation is isometric in the frame coordinates. At the finitely many cutoffs where the calibrated
Source: A Wilson Yang–Mills Construction: A Natural-Language Mathematical Exposition. Both papers belong to one Zenodo record. No external funding.