Robust Phase-to-Record Conversion with Retained Loss Outputs
A calibrated filter with common uncertain conversion
A calibrated filter with common uncertain conversion
The original source population and the two physical stages
Keep the preparation-uncertainty construction’s one-excitation source family
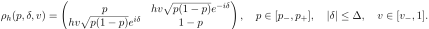
Searchable transcription
(︄
p
hv
√︁
p(1 −p)e−iδ
)︄
ρh(p, δ, v) =
,
p ∈[p−, p+],
|δ| ≤∆,
v ∈[v−, 1].
hv
√︁
p(1 −p)eiδ
1 −p
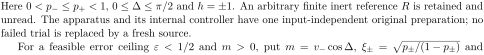
Searchable transcription
Here 0 < p−≤p+ < 1, 0 ≤∆≤π/2 and h = ±1. An arbitrary finite inert reference R is retained and
unread. The apparatus and its internal controller have one input-independent original preparation; no
failed trial is replaced by a fresh source.
For a feasible error ceiling ε < 1/2 and m > 0, put m = v−cos ∆, ξ± =
√︁
 and
 arcosh
 )]. The previous source theorem, or direct calculation of the two rank-one reader effects, gives the allowed amplitude-ratio interval

Searchable transcription
a = e−hε/ξ−,
b = ehε/ξ+.
(30)
We develop the case 0 1, where mode zero should be attenuated; interchanging source modes treats the reflected case. The interval exists at or above the previously proved conditional-error floor. For any effective ratio
 the worst conditional error is
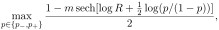
Searchable transcription
max
p∈{p−,p+}
1 −m sech[log R + 1
2 log(p/(1 −p))]
2
,
so the error ceiling is equivalent to First place a calibrated, static passive filter at the entrance:
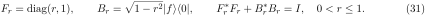
Searchable transcription
Fr = diag(r, 1),
Br =
√︁
1 −r2|f⟩⟨0|,
F ∗
r Fr + B∗
rBr = I,
0 < r ≤1.
(31)
The reflected mode is retained and never interacts with the subsequent cell. This is a unitary beam-splitter isometry with one additional vacant mode. For example an exchange Hamiltonian with angle arccos
 implements it; its interaction entries have units
 arccos
 for a finite calibrated prefix duration
 . Its phase must also be calibrated or charged to ∆. This prefix is an additional declared resource. It is outside the uncertain conversion cell; its own losses are included in its calibrated amplitudes, not presumed absent in a real device. The comparison uses the same prefix interval with a bypass for the unfiltered apparatus. The quoted internal time uncertainty concerns the following cell; total elapsed time also includes
 . No instantaneous filter or unchanged total hardware is asserted. Next use identical path couplings. In the bright-flag basis the ready/flag Hamiltonian and all internal interactions are path independent:
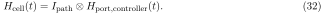
Searchable transcription
Hcell(t) = Ipath ⊗Hport,controller(t).
(32)
Searchable transcription
For the simple resonant cell this is the four-mode model with C(t) = g(t)H, where H = 2−1/2(︁1 1
1 −1
)︁.
Uniform ready-subspace loss preserves the path state while transferring its excitation to retained lost
modes. The full loss dynamics must be path blind; equal population decay rates alone do not exclude
additional path dephasing. The bath and controller are retained. The physical + and −flags read
⟨±x| = 2−1/2(⟨0| ± ⟨1|) once the cell is off. Null, filter failure, source remainder and lost modes are
inconclusive; no additional reader of them or of R is included.
Exact factorization under unknown common internal dynamics
Proposition 4.1 (Internal uncertainty changes exposure, not reader ratio). For any path-blind cell with its stated original input-independent stock, there is a positive retained controller/bath output on the flag branch, independent of the path input, with Tr
 . The conclusive instrument on any
 has the exact form
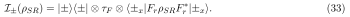
Searchable transcription
I±(ρSR) = |±⟩⟨±| ⊗τF ⊗⟨±x|FrρSRF ∗
r |±x⟩.
(33)
Searchable transcription
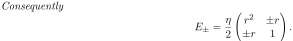
Consequently
(︄
r2
±r
±r
1
)︄
E± = η
.
2
All conclusive conditional errors and normalized reference assemblages are independent of unknown common gain, detuning, loss, waveform or stopping time, whenever that branch has nonzero probability. Their common conclusive scale can change and can even vanish. A positive rate requires a separate lower bound on

Proof. Purify the apparatus stock with its inert original purifier. In the transmitted branch, the full path-independent cell isometry acts as identity on the path and reference and as one common isometry on the ready-port/controller stock. Projecting the latter to the flag port gives a subnormalized apparatus vector whose projector, or the corresponding mixture, is . Projecting the path into the physical
 flag modes gives (33). Its trace supplies the stated effects. The apparatus state conditional on either conclusive flag is the same
 , independent of the input and reported label. The reference factor is the displayed matrix element; after normalization it has no
 dependence. The filter-failure amplitude
 and every remaining ready/lost-port amplitude are retained orthog-onal output sectors. Combining the filter isometry with the full cell isometry makes their complete sum trace preserving and retains coherences if the output is left unmeasured. This does not claim that full outputs for two different internal cells are equal:
 , lost temporal modes and cross-sector phases can differ. The invariance is the exact specified reader/reference interface. No reset or redraw is used, and tensoring with
 incurs no reference-dimension cost.
For an original ensemble of unknown internal parameters, retain that ensemble label and its apparatus state. The same formula holds with the corresponding mixture of , since the stock is independent of the unknown input. There is no fresh statistical independence across uses: one unknown common cell can correlate their success flags. Pointwise error guarantees do not turn those flags into independent trials. Among calibrated diagonal filters followed by a common cell known only to obey
 0, the sharp maximin rate is
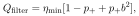
 (34)
Indeed the error constraint is ], and for
 1 the original population’s conclusive rate is
 ], smallest at
 and at
 and increasing with
 . Allowing an extra common attenuation cannot improve it. This is a sharp optimum in this filter/common-conversion subclass; it is not an unrestricted robust-control optimum.
Sharp gain/loss/time box bounds
For a constant positive resonant coupling , scalar ready loss
 and interaction duration
 , define the positive flag amplitude before its first maximum by
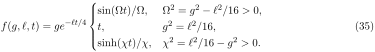
Searchable transcription
sin(Ωt)/Ω,
Ω2 = g2 −l2/16 > 0,
t,
g2 = l2/16,
sinh(χt)/χ,
χ2 = l2/16 −g2 > 0.
⎧
⎪
⎪
⎨
f(g, l, t) = ge−lt/4
(35)
⎪
⎪
⎩
Its first ready-amplitude zero occurs at
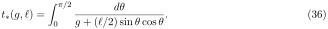
Searchable transcription
t∗(g, l) =
∫︂π/2
0
dθ
g + (l/2) sin θ cos θ.
(36)
This is the arctangent/critical/hyperbolic formula of the coherent conversion result. Let actual constants obey

Searchable transcription
g ∈[gL, gU],
l∈[lL, lU],
t ∈[tL, tU],
0 < gL ≤gU,
0 ≤lL ≤lU,
0 < tL ≤tU,
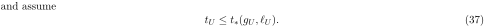
Searchable transcription
and assume
tU ≤t∗(gU, lU).
(37)
The gain and loss are in s ; the duration is in seconds. This is uncertainty in one rectangular pulse’s constants and clock duration, not a bound for arbitrary time-varying coefficients taking values in those intervals.
Proposition 4.2 (Exact transfer and ratio corners). In this box, increases with
 and
 and decreases with
 . Thus
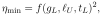
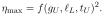 (38)
For a fixed relative coupling define
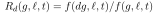 . Its exact extrema are
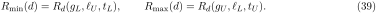
Searchable transcription
Rmin(d) = Rd(gL, lU, tL),
Rmax(d) = Rd(gU, lL, tU).
(39)
It increases with and decreases with
 , and is increasing in

Proof. Equation (36) decreases in both and
 , so the entire box precedes each pulse’s first ready zero. Since ̇
 for its nonnegative ready amplitude
 increases in time. For the gain and loss derivatives put
 4. In the oscillatory case

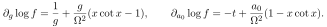
Searchable transcription
∂g log f = 1
g + g
Ω2 (x cot x −1),
∂a0 log f = −t + a0
Ω2 (1 −x cot x).

Searchable transcription
For t ≤t∗, x ≤arctan(Ω/a0). The decreasing function x cot x is at least arctan z/z ≥1/(1+z2) = a2
0/g2,
z = Ω/a0, which proves the gain derivative is nonnegative. Also 1 −x cot x ≤x tan x and a0 tan x ≤Ω,
which prove the loss derivative is nonpositive. In the hyperbolic case y = χt the derivatives are
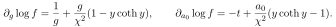
Searchable transcription
∂g log f = 1
g + g
χ2 (1 −y coth y),
∂a0 log f = −t + a0
χ2 (y coth y −1).
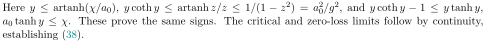
Searchable transcription
Here y ≤artanh(χ/a0), y coth y ≤artanh z/z ≤1/(1 −z2) = a2
0/g2, and y coth y −1 ≤y tanh y,
a0 tanh y ≤χ. These prove the same signs. The critical and zero-loss limits follow by continuity,
establishing (38).
For the ratio use the entire sine product, which also covers imaginary Ω:
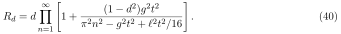
Searchable transcription
∞
∏︂
[︄
1 +
(1 −d2)g2t2
]︄
Rd = d
.
(40)
π2n2 −g2t2 + l2t2/16
n=1
All denominators are positive in the prepeak box. Each factor increases in and decreases in
 . The product converges uniformly on compact subsets of this box, so its limits preserve those monotonicities. This gives (39). Increasing
 increases its numerator amplitude
 ) by the gain result; the denominator is fixed.
A solved, optimized comparison with unequal taps
The earlier rectangular-pulse subclass has no calibrated input filter and uses H diag
 1) with one fixed
 chosen before unknown
 . It is the actual unequal-tap architecture, retuned for the whole uncertainty box rather than frozen at its nominal value. Its conditional error is controlled by the effective ratio
 . For 0
 1, all pulses in the box are valid exactly when

Searchable transcription
Rmin(d) ≥a,
Rmax(d) ≤b.
(41)
Searchable transcription
Both functions increase from zero to one. The feasible coupling interval is [R−1
min(a), R−1
max(b)], if
nonempty. Its sharp maximal rate is attained at
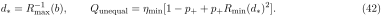
Searchable transcription
d∗= R−1
max(b),
Qunequal = ηmin[1 −p+ + p+Rmin(d∗)2].
(42)
To prove the rate statement, both individual transfer amplitudes increase with gain and time and decrease with loss. Thus their weighted conclusive sum is smallest at ( ) and
 increases with
 , giving the largest feasible value (42). This is a solved restricted minimax, not a sampled optimizer. If the feasible interval is empty, this rectangular unequal-tap subclass has no positive-rate valid design. Whenever the box creates strict ratio variation,
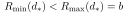 , comparison of (34) and (42) gives
 . The calibrated filter fixes the desired ratio outside the uncertain conversion dynamics. It does not cancel loss or recover a missing input sample. That improvement consumes the extra resource specified at the start. A shaped pulse or larger controller could outperform either restricted subclass; no bound on such a protocol is claimed.